SOMEWHERE ON EARTH
v1.0 platform release
Open hardware · open software
Made open, made repeatable.
Build your own$8,056in parts · open Buy oneSoonjoin the list
Mobile Bimanual Robot · Open Platform

A robot that does the work.

56 functional DOF. Two 17-DOF hands, a holonomic base, and an $8,056 parts subtotal. Open hardware and software.

Scroll

1. Abstract

As robot learning moves beyond the tabletop, many tasks require mobility, adjustable reach, active perception, and bimanual dexterity. Commercial platforms combining these capabilities are costly, while affordable open-source alternatives cover only a subset and require software integration. We present MABEL, an open-source anthropomorphic mobile bimanual robot with 56 degrees of freedom (DOF) and a US$8.1k parts cost. It combines two 7-DOF arms with 17-DOF hands, a pitching torso, a lift, a 3-DOF head, and a holonomic base. Back-drivable arms and torso support compliant interaction, with fingertip reach from floor level to 2.23 m. The head and torso roughly triple modeled camera coverage relative to a torso-fixed camera. Apple Vision Pro head and hand tracking enables whole-body teleoperation without handheld controllers, with 137 ms mean glass-to-glass stereo video latency over the robot's Wi-Fi hotspot. We demonstrate an end-to-end imitation learning pipeline, from teleoperated data collection to policy deployment, using a shared command interface and whole-body controller.
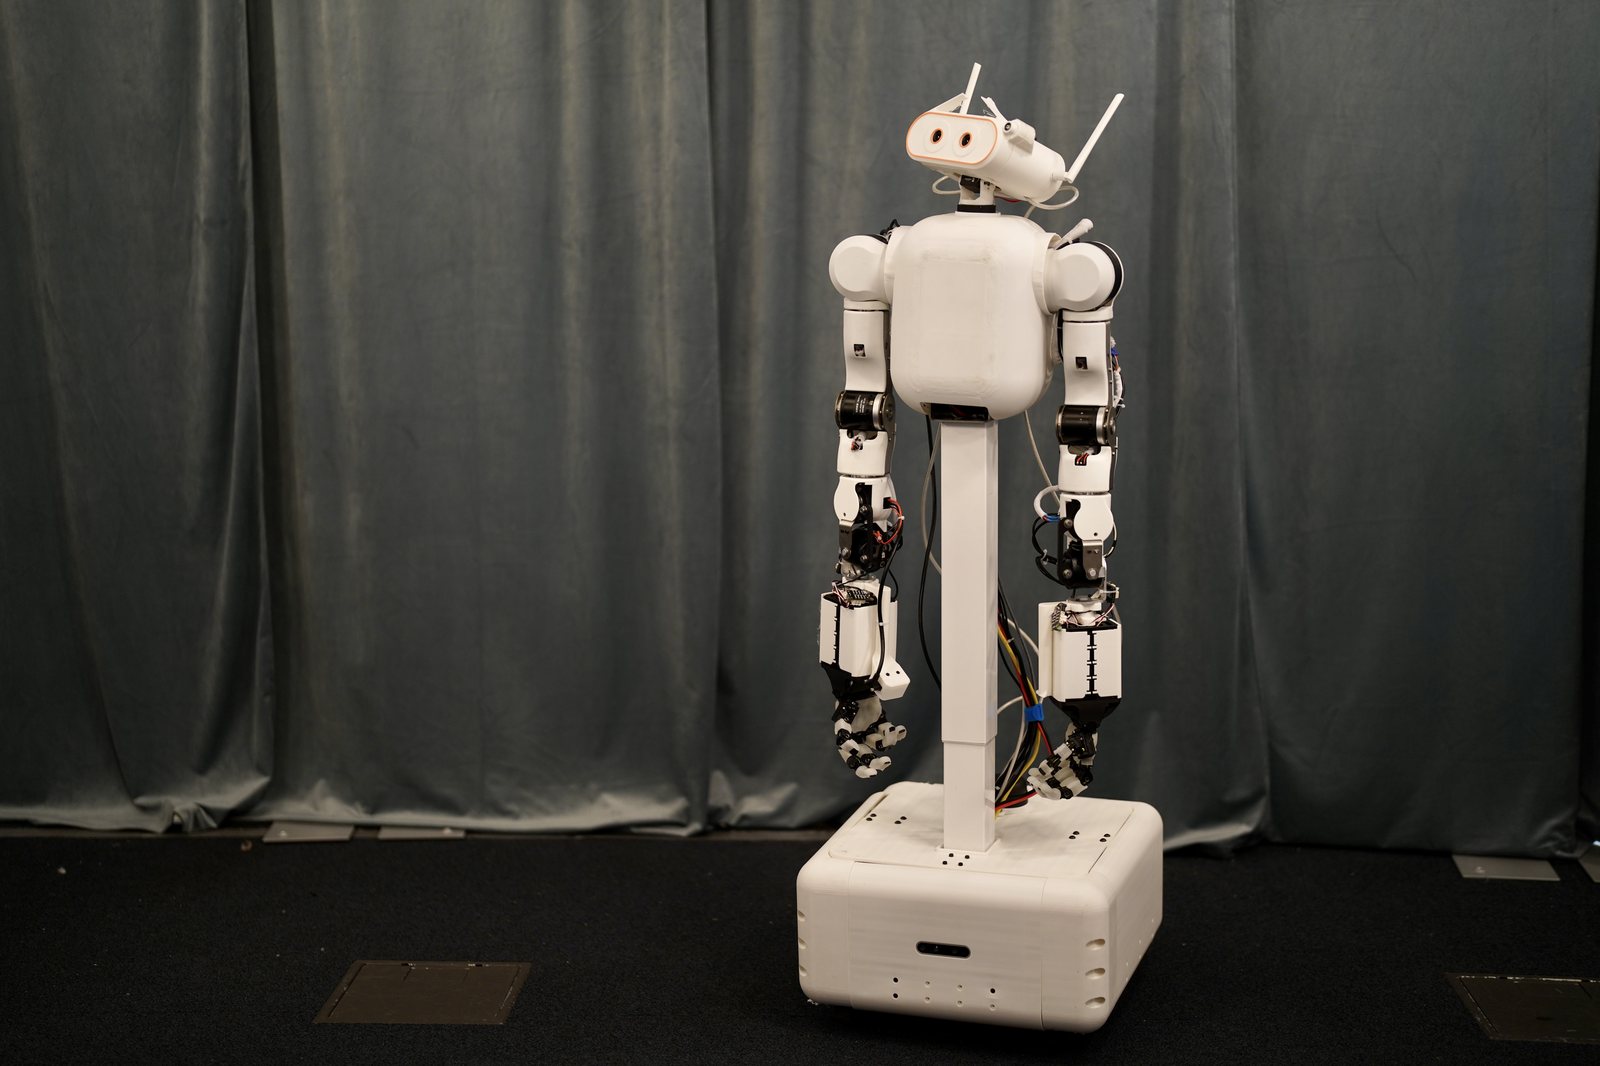
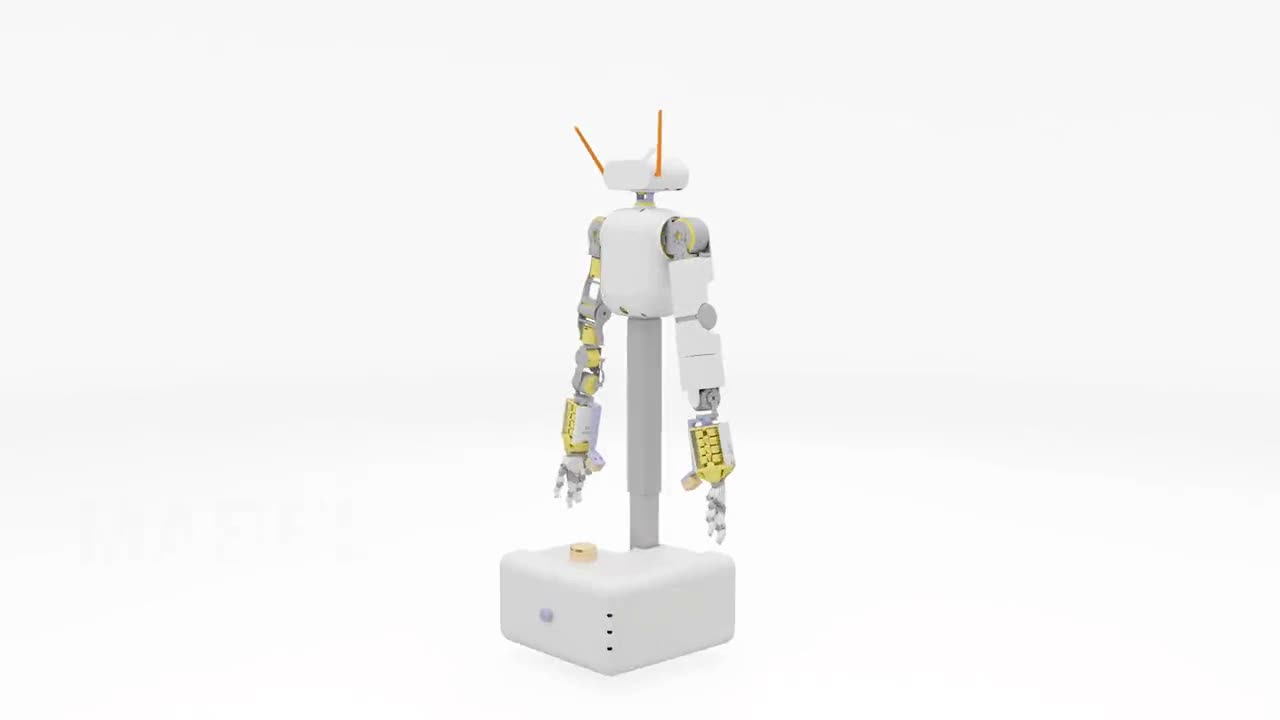
MABEL as built: white shells, two ORCA hands, holonomic base

Open-source hardware

Whole-body teleoperation

Shared software stack

2. Real robot photos

01 / 03

Shop

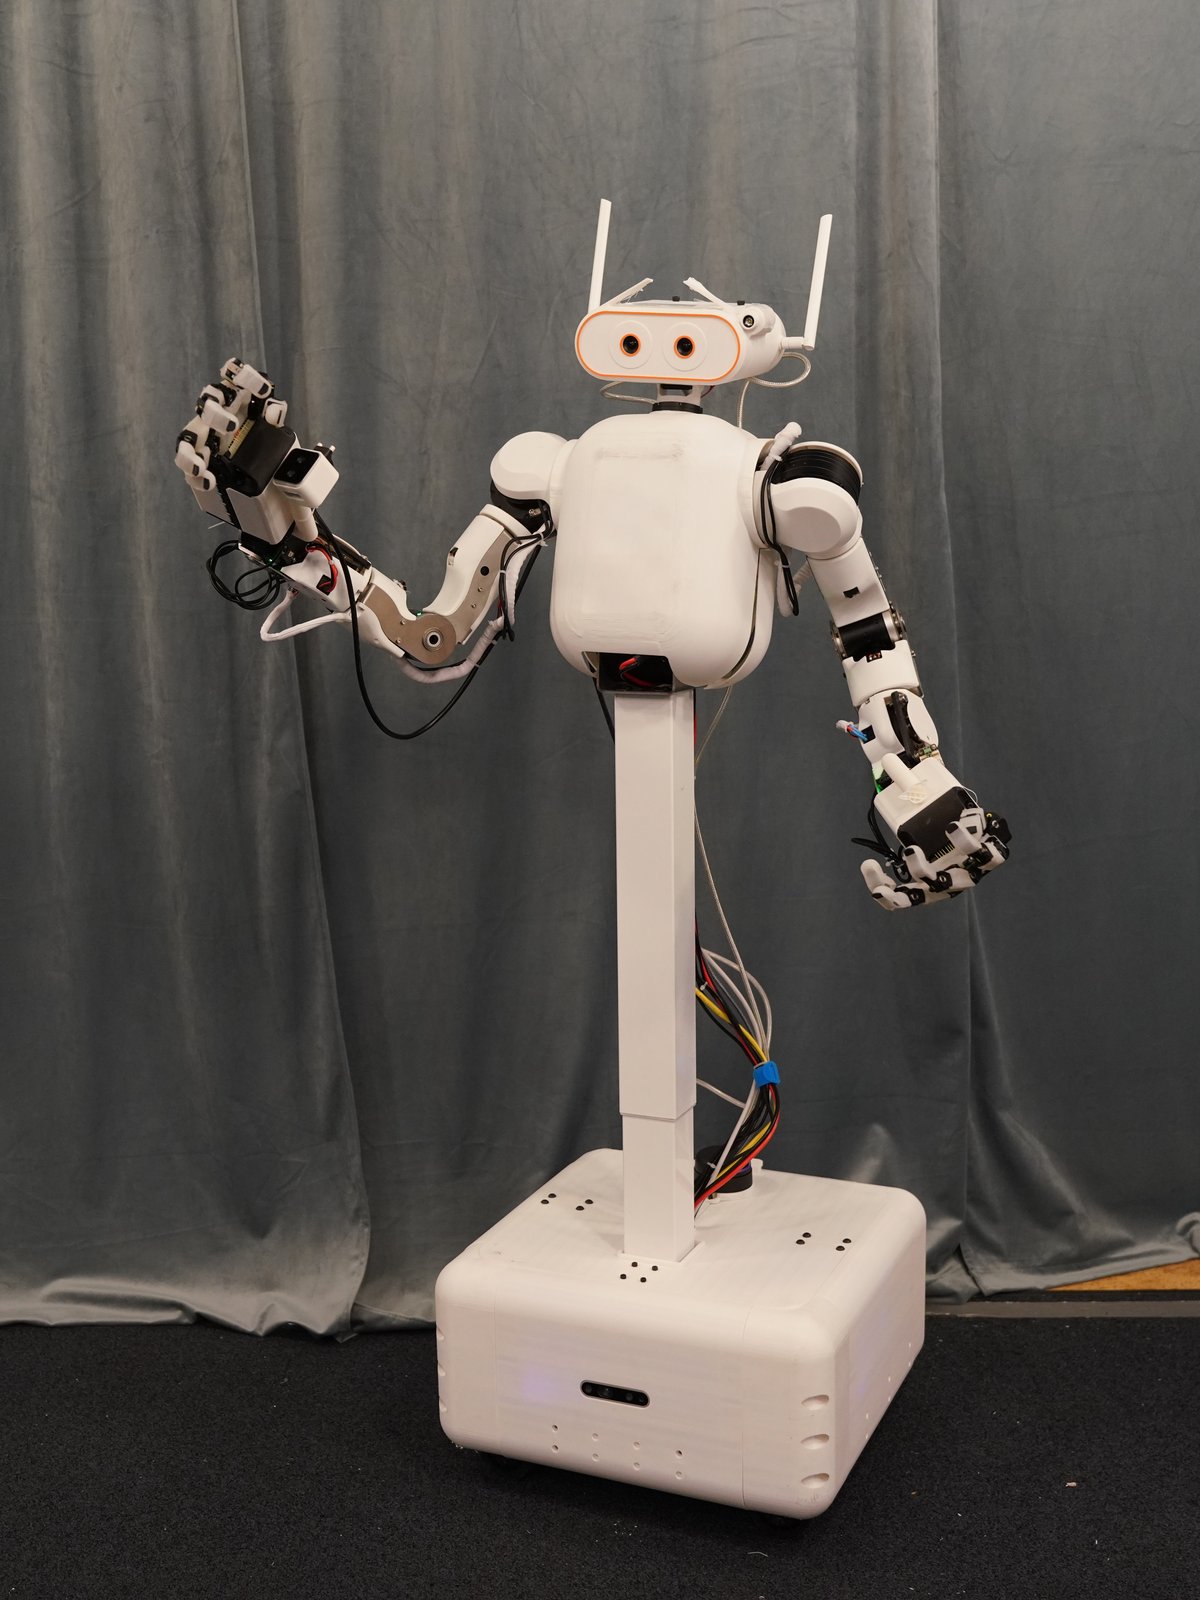
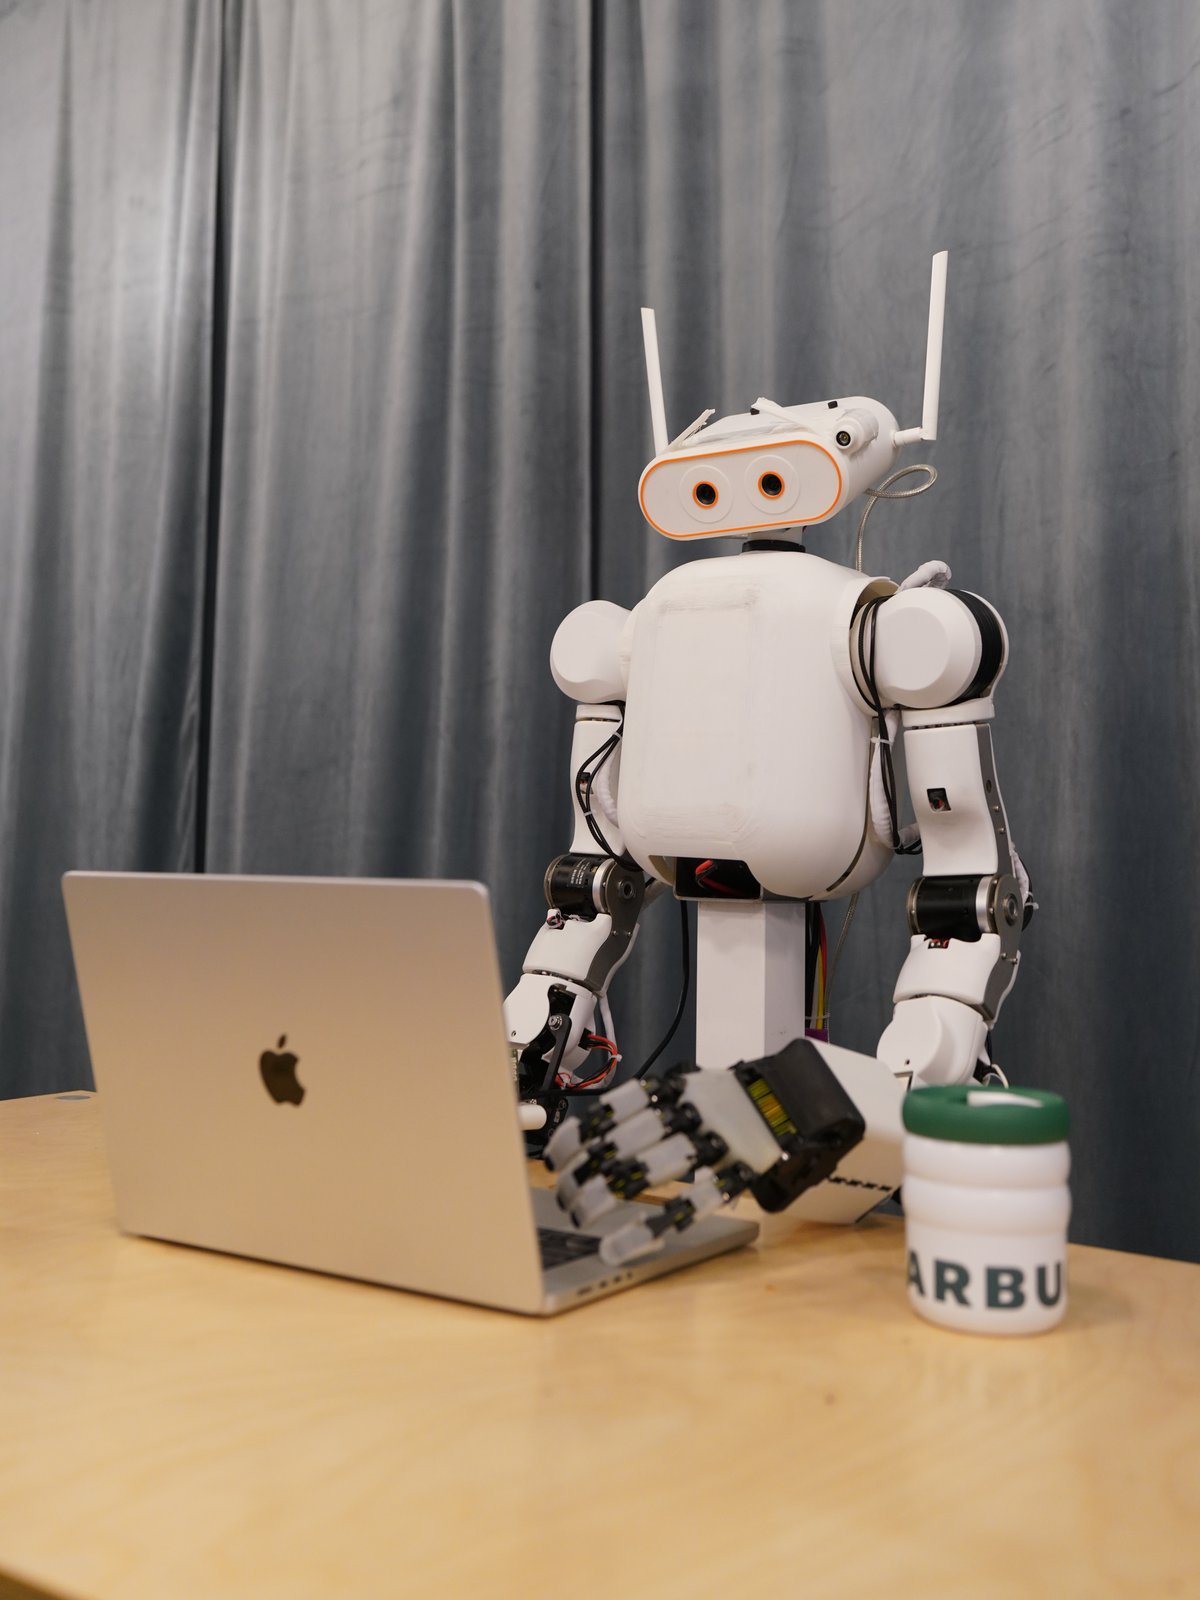
MABEL standing in front of a grey curtain
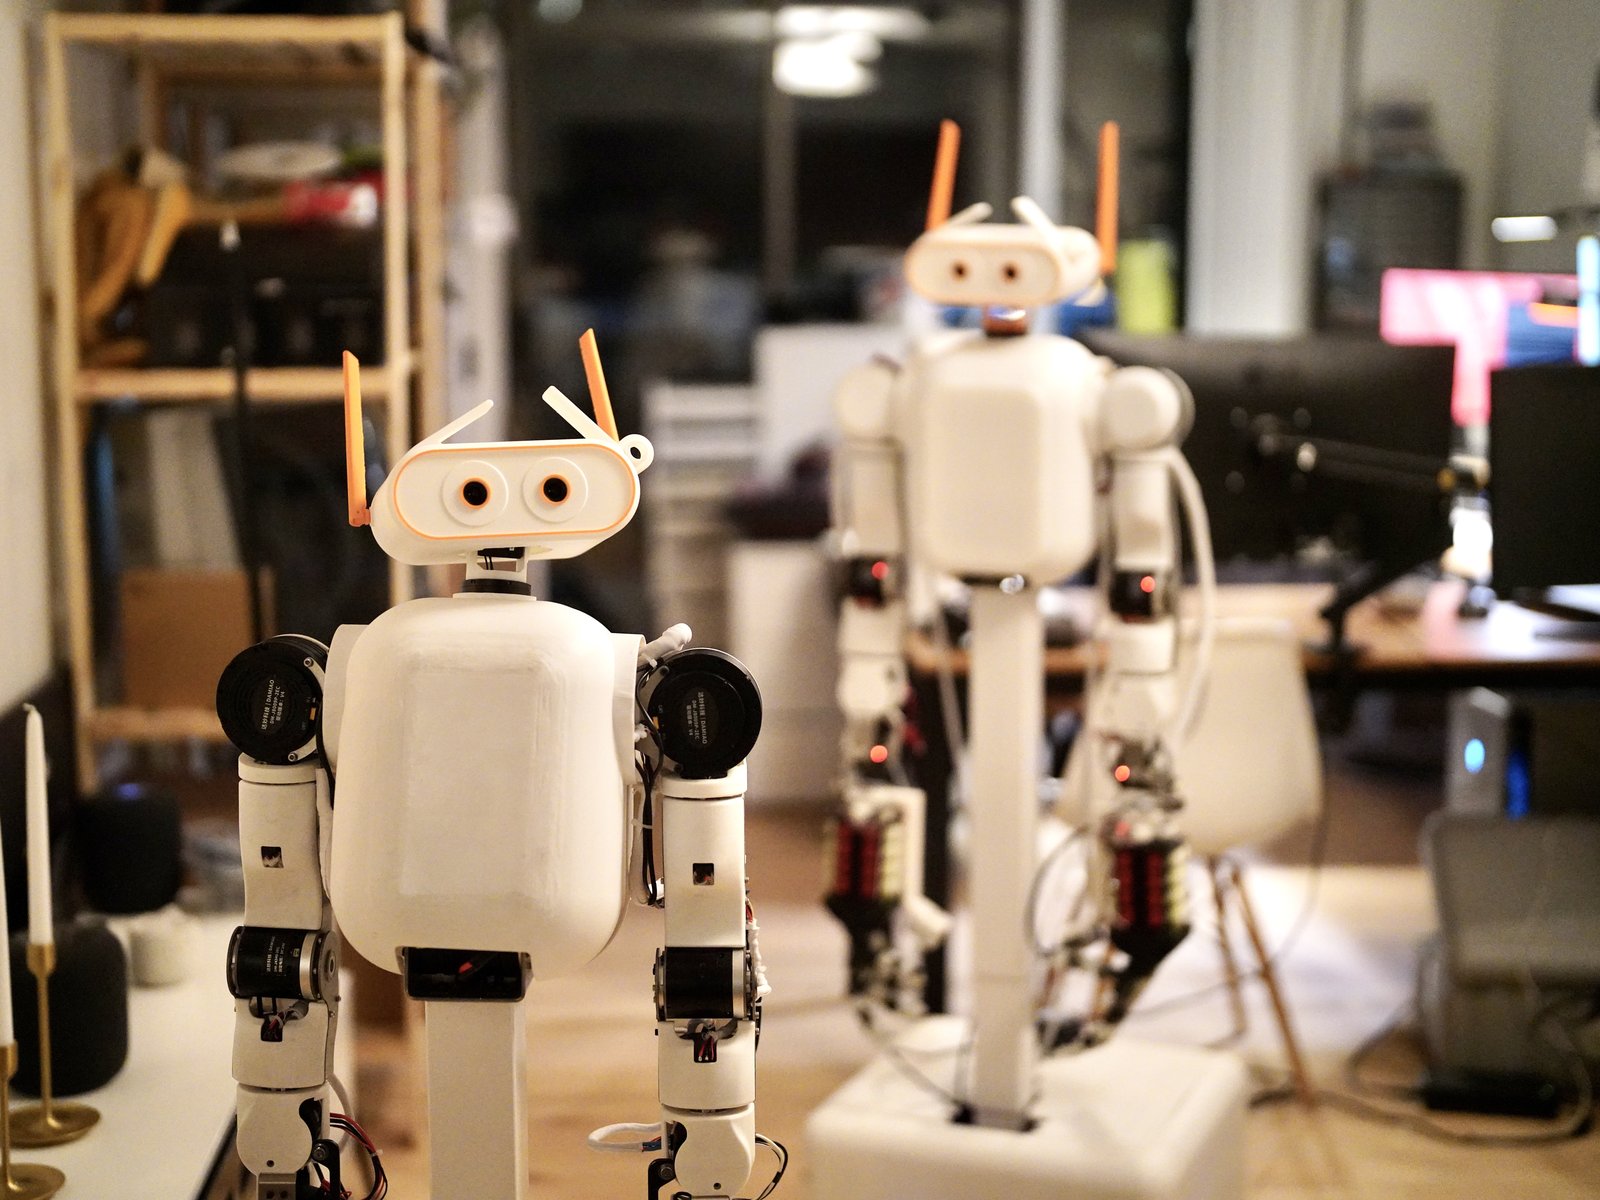
Two MABEL robots in the lab
1.5×
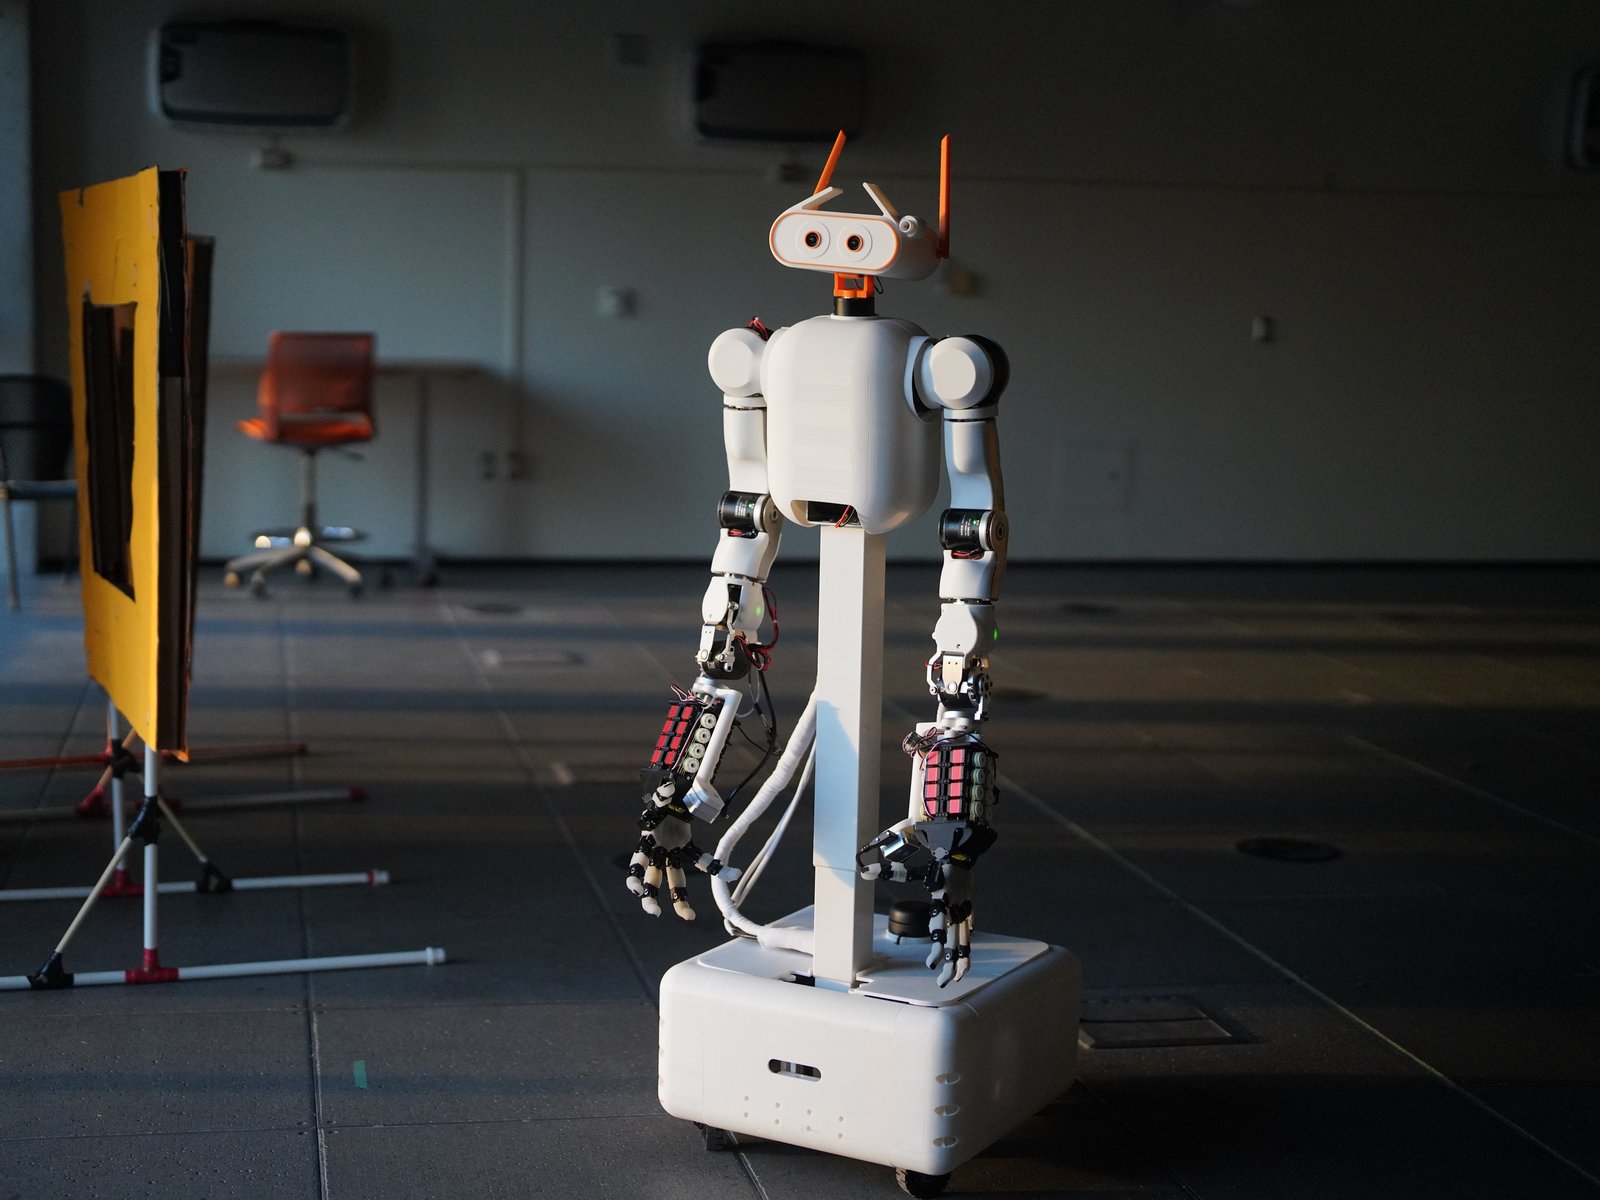
MABEL in an empty hall
02 / 03

Home

2×
MABEL at a laptop on a desk
2.4×
4×
4×
7.3×
3.9×
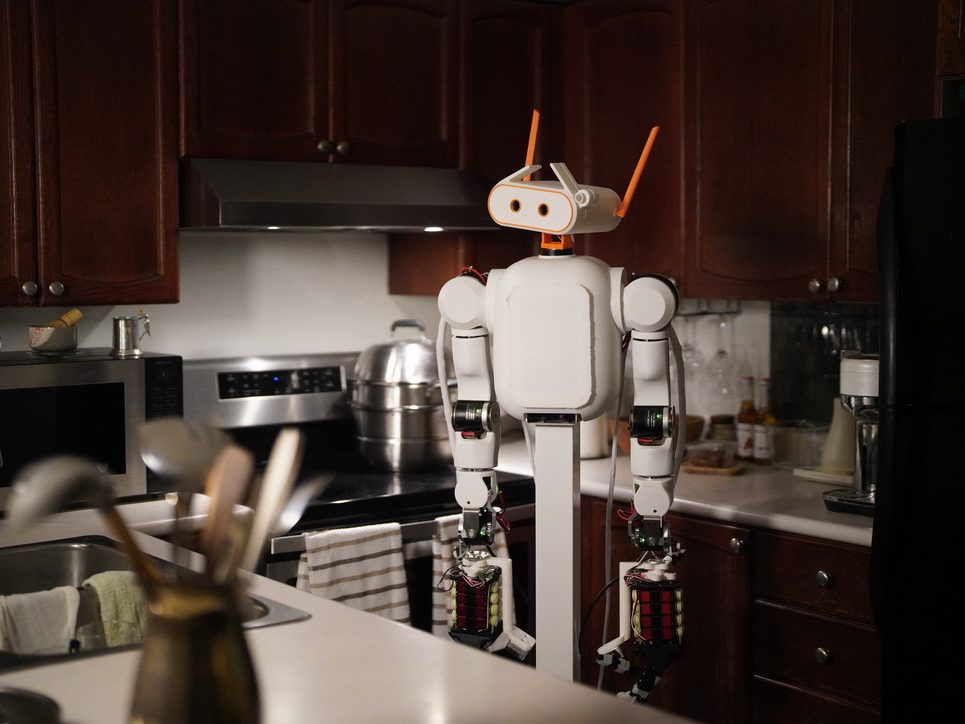
MABEL standing in a home kitchen
4.0×
03 / 03

Street

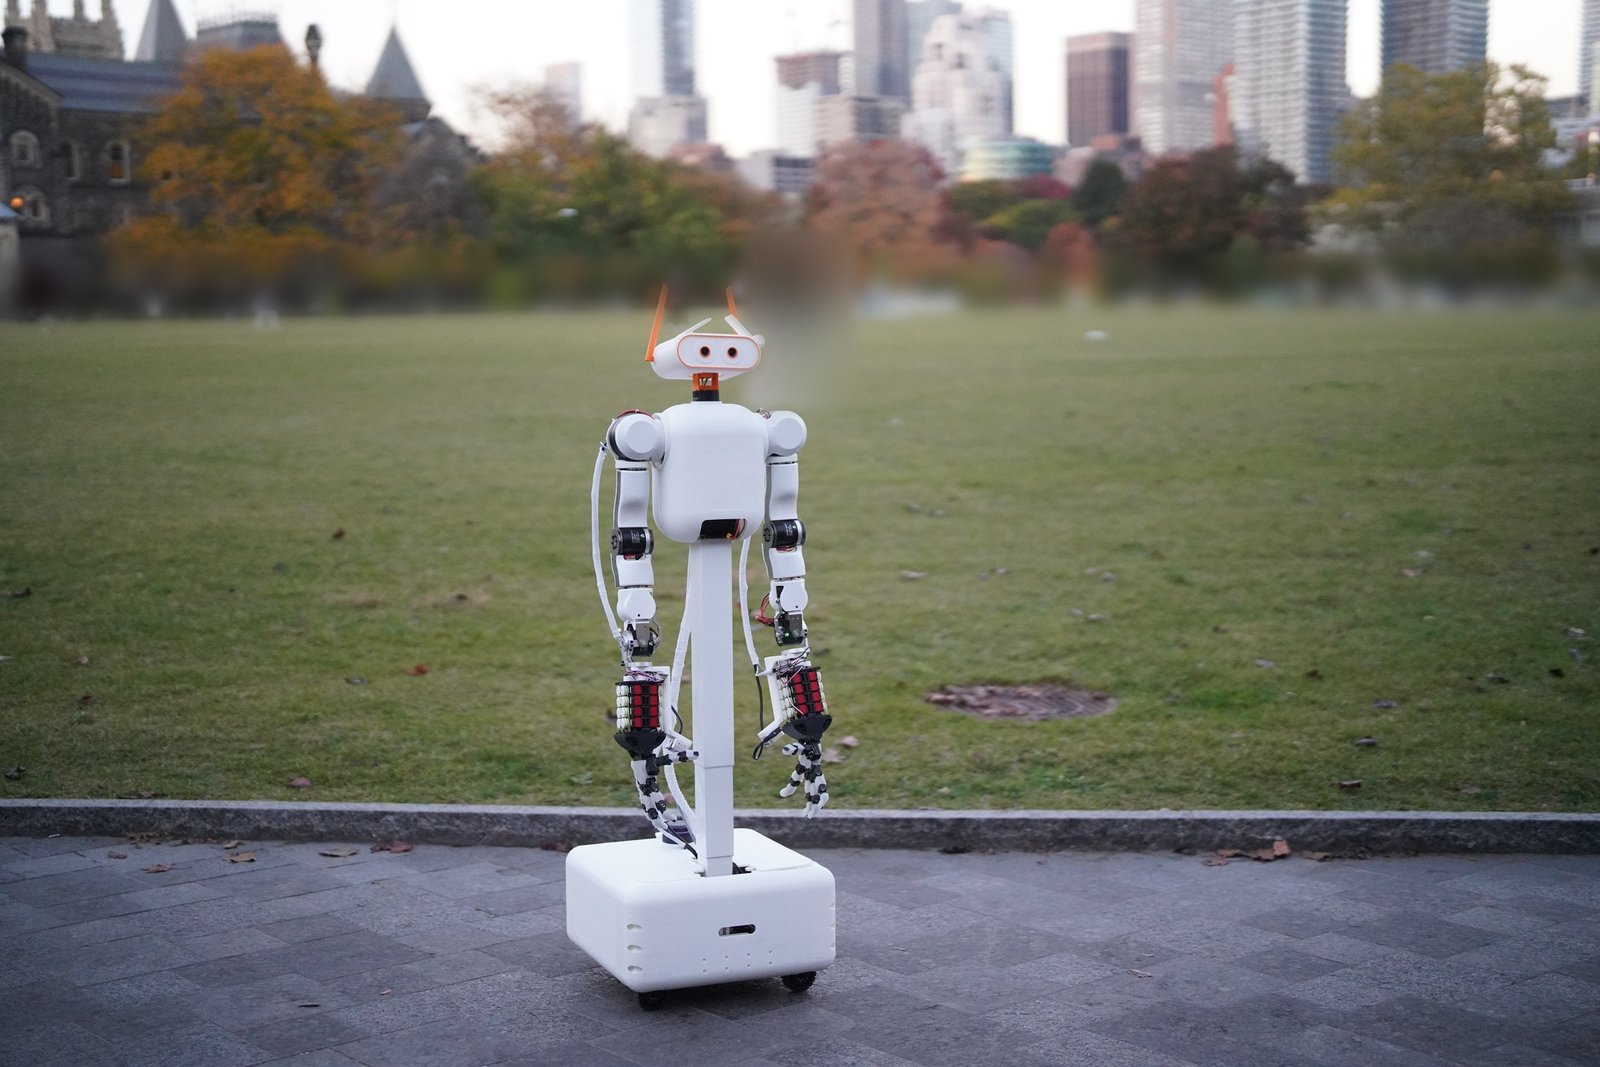
MABEL on a paved path beside a lawn, city towers behind
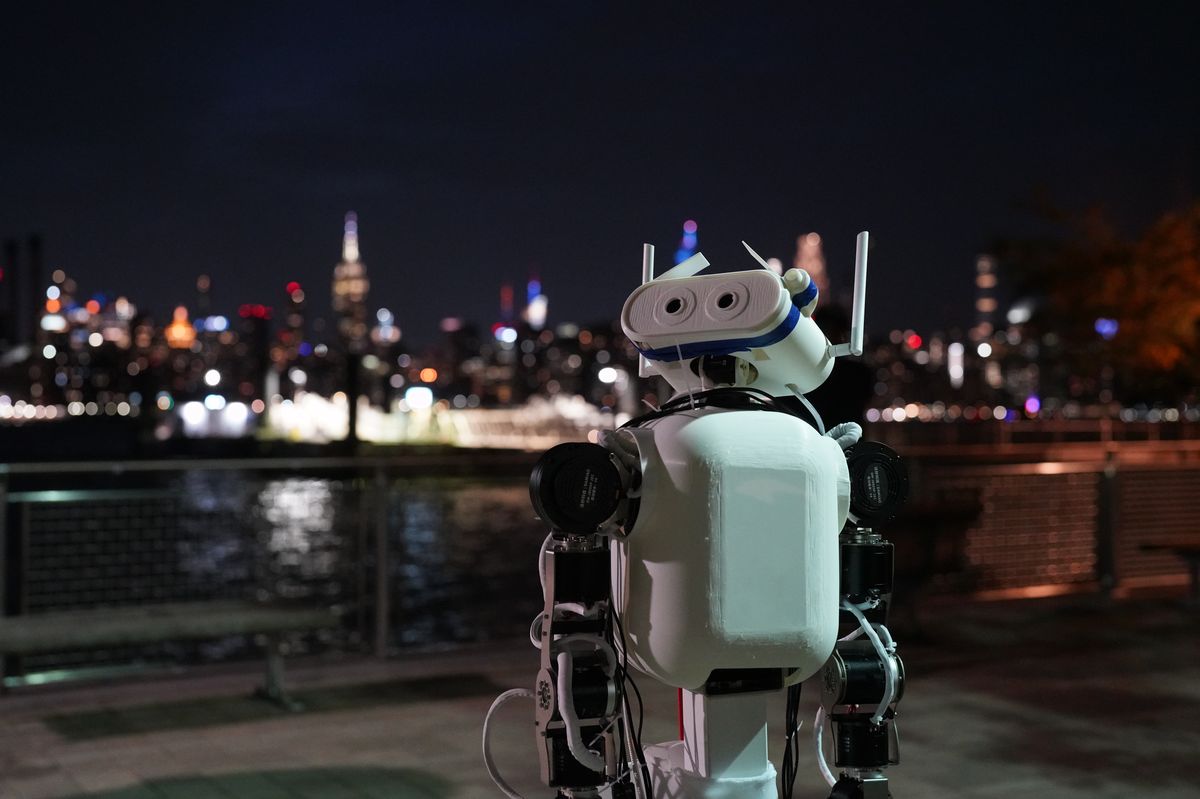
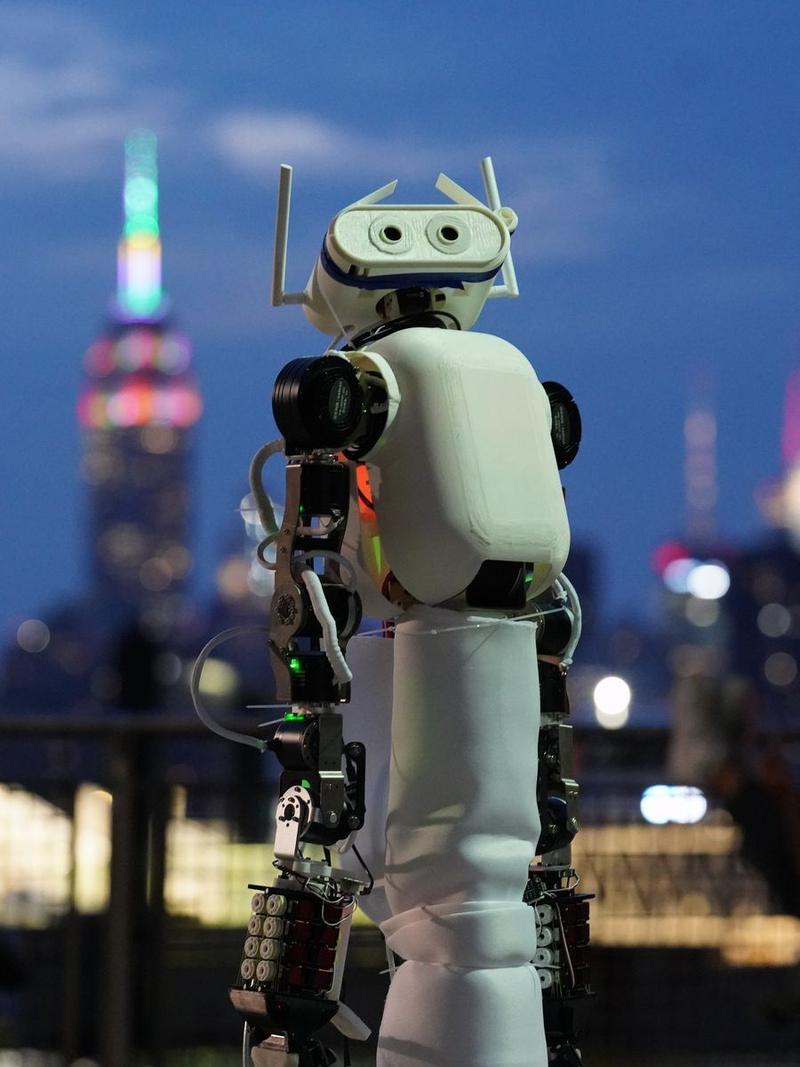
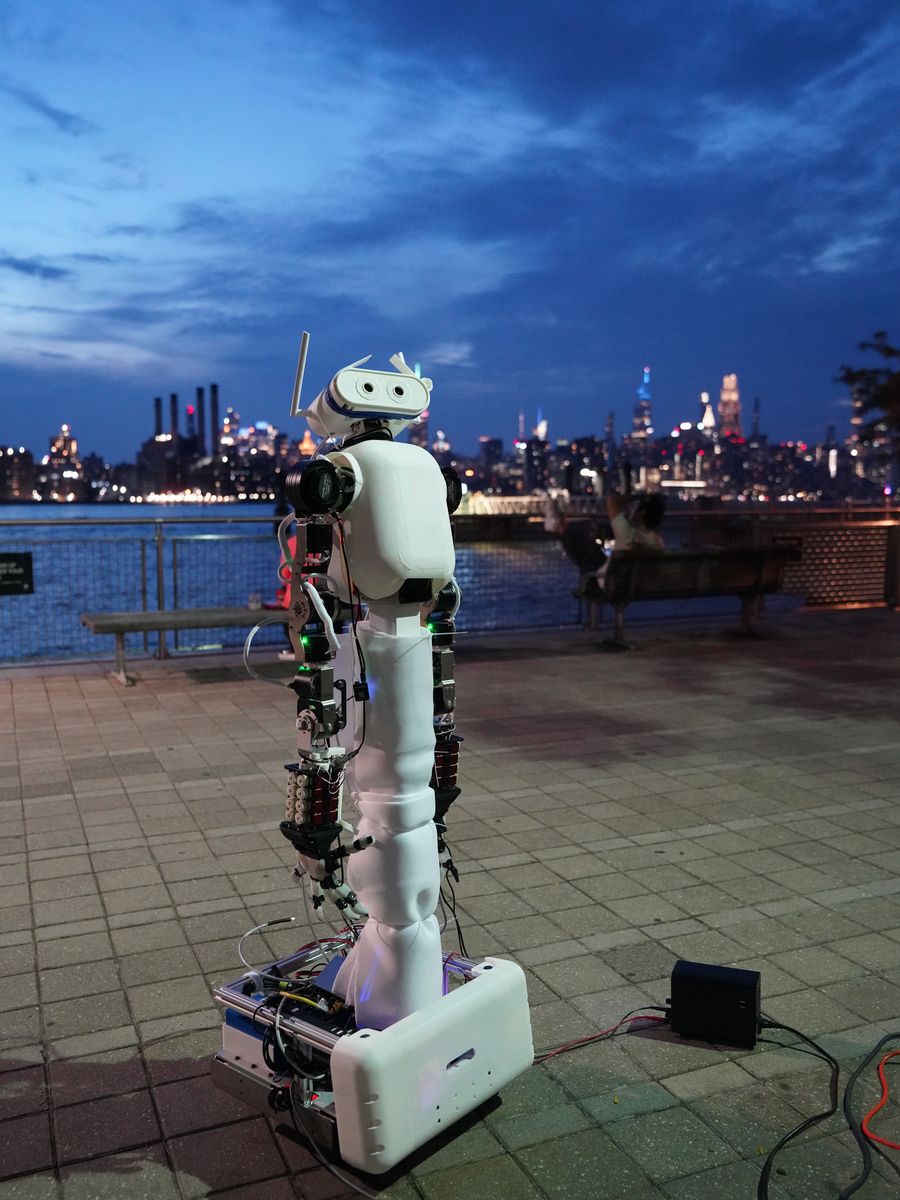
MABEL on the waterfront at night, Manhattan behind
MABEL in front of the Empire State Building at dusk
MABEL on the East River waterfront at dusk
2×

3. State-of-the-art robots

4. Hardware design

Loading MABEL model…
MABEL modular hardware render

Specifications

Workspace and reach

Reach · floor to overhead

tablehigh shelf MABEL0.00–2.23HUMAN0.00–2.18MOBILE ALOHA0.65–2.00YOR0.00–1.86TIDYBOT++0.00–1.28XLEROBOT0.50–1.25 012FINGERTIP HEIGHT · METRES

Envelope · measured

Where the fingertip can actually go. Blue is the arm alone, lift down; green is the same arm over the whole 0.635 m stroke — the gap between them is what the lift buys. Rejection-sampled forward kinematics over the arm’s own joint limits, 24,000 samples per height, from the same MuJoCo model the robot is built to; the torso range is read from its joint limits.

5. Teleoperation

Local mode

Global mode

Tracking, cameras and latency

The Vision Pro streams head and hand poses at 60 Hz and displays the robot’s stereo view. Mean glass-to-glass video latency is 137 ms on the robot’s hotspot, 150 ms on LAN and 161 ms over Tailscale. The iOS app also provides joystick control. Teleoperation details →

6. Simulation

MuJoCo

Isaac Sim / Isaac Lab

Digital-twin model

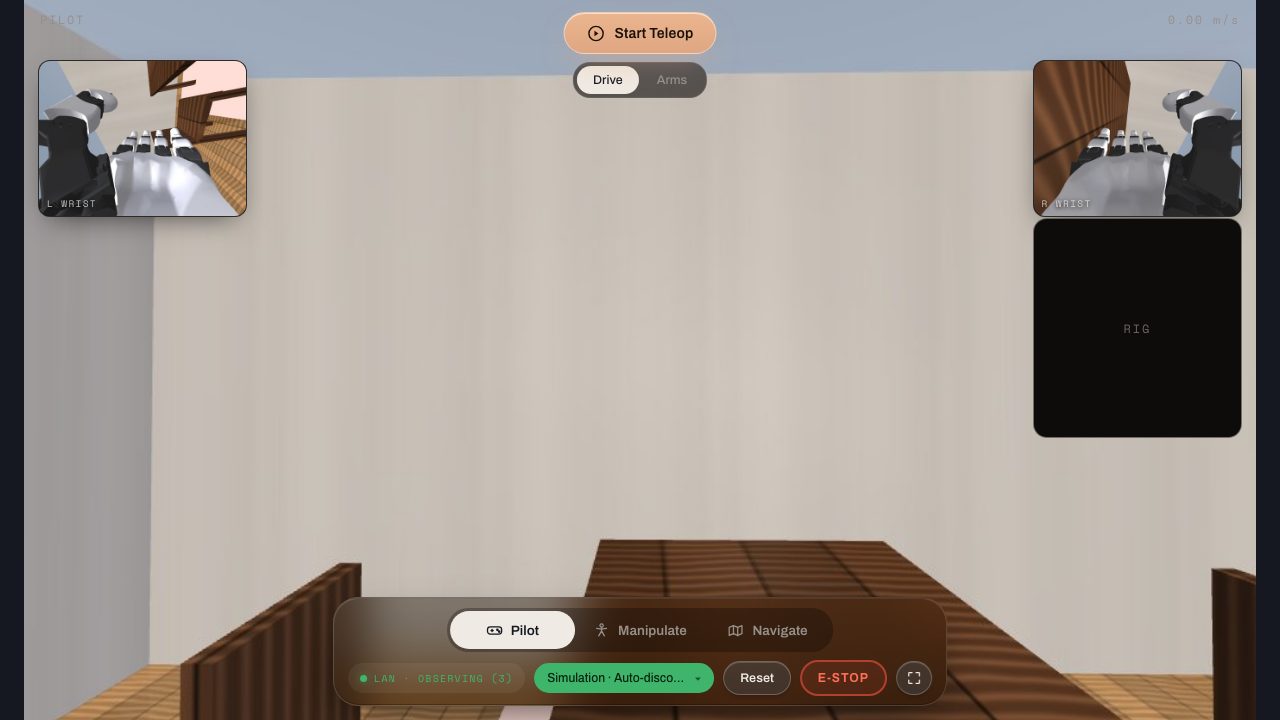
Interactive simulation

Open full screen ↗
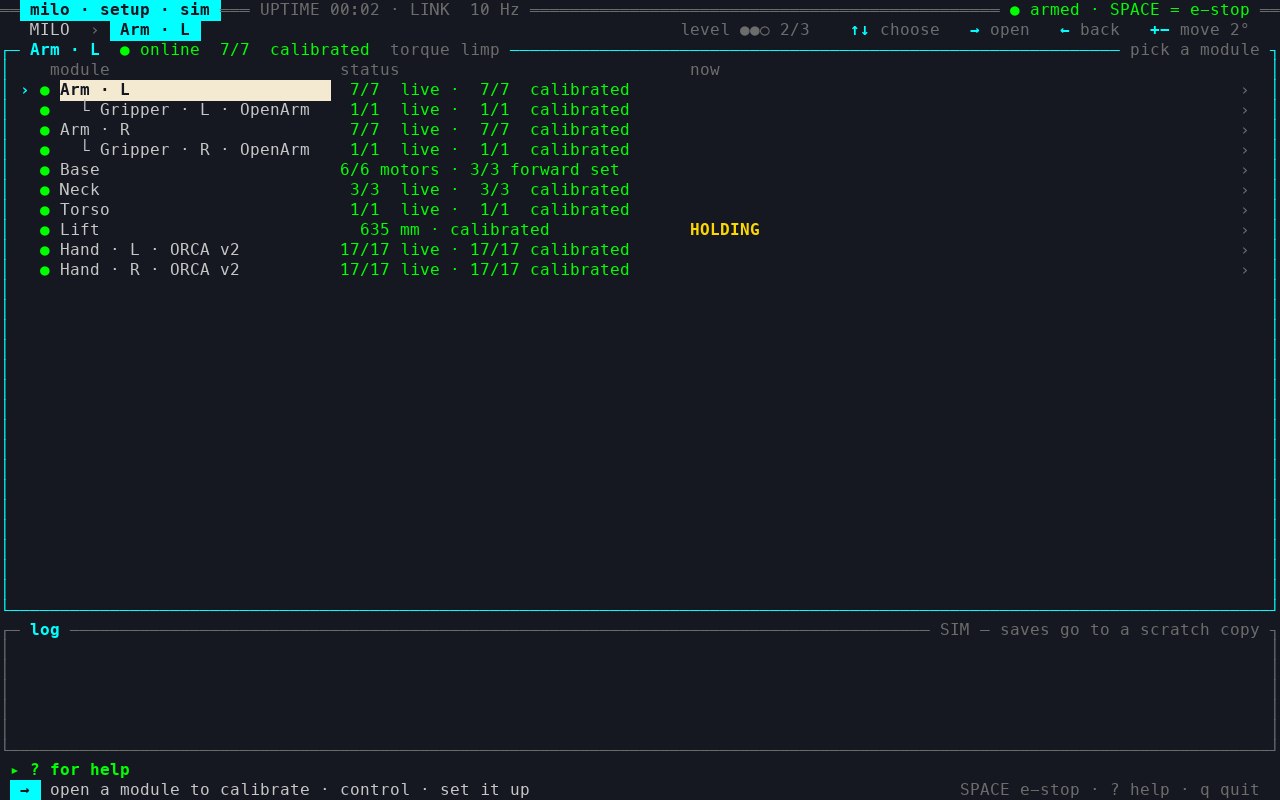
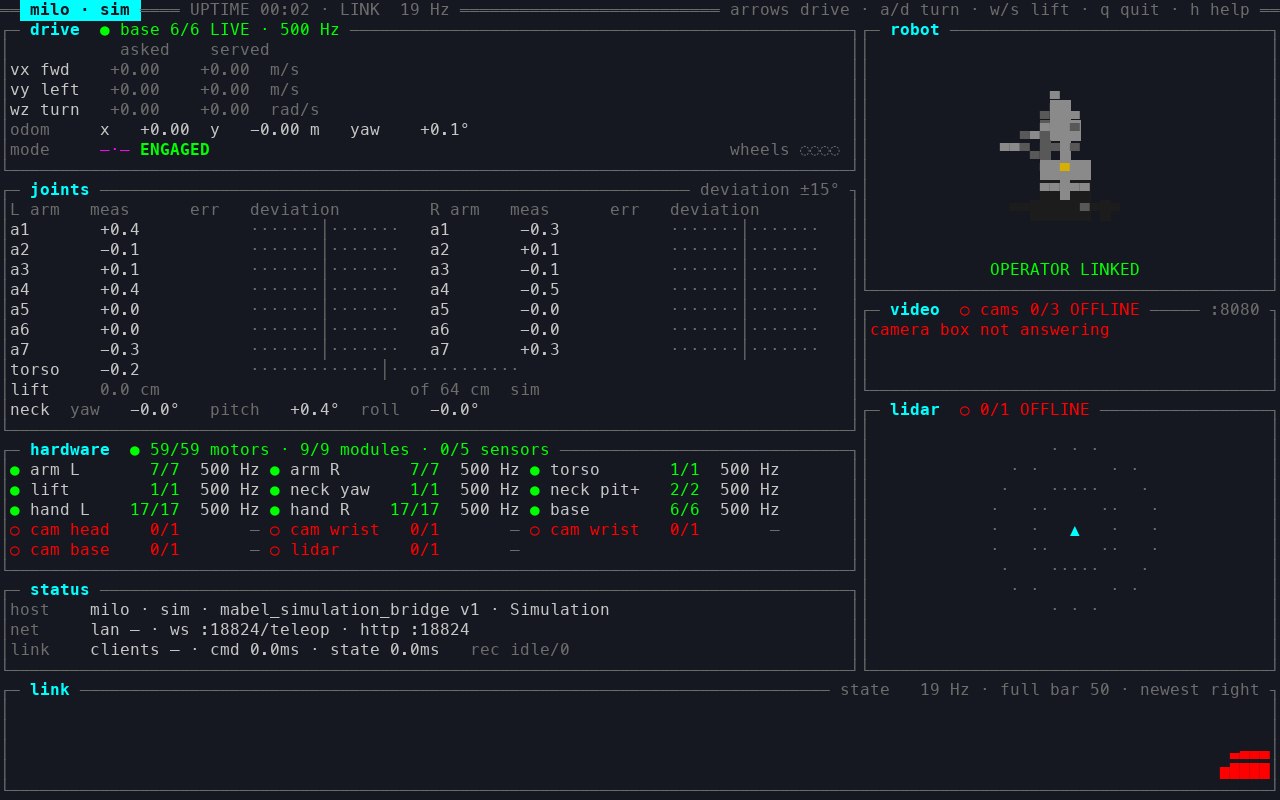
MABEL simulation console

7. Control, retargeting and motion model

Whole-body retargeting

Sparse head and hand tracking is mapped to the arms and torso, hands, and neck under their kinematic constraints.

Retargeting implementation →
Compliant control

Gravity and friction feed-forward support low-gain, back-drivable arm and torso motion.

Controller details →
Height-aware motion limits

Base speed and acceleration limits depend on lift height to reduce tip-over risk.

Motion model →

8. Learning and architecture

Hardware bridge → robot

  1. CollectRecord hand-grasping demonstrations.
  2. CurateAlign camera views and measured state.
  3. TrainPredict 4 s of actions with ACT.
  4. DeployExecute 1 s, then observe again.

Predict 4 s. Execute 1 s.

Execute · 1 sPrediction · 3 s

Learning details →
The paper

Paper and source

The system paper documents the hardware, teleoperation, control, simulation and learning pipeline. Design files, software and build documentation are available in the repository.

GitHub repo ↗
@misc{mabel2026,
  title  = {{MABEL}: An Open Anthropomorphic Mobile
            Bimanual Platform for Teleoperation
            and Learning},
  author = {Anonymous (under review)},
  year   = {2026},
  note   = {robotmabel.github.io/website}
}
Development tools

Hardware · Teleoperation · Simulation · Learning · Development harness · Build documentation

MABEL · Video submission

Press play to watch the final submission with sound.

Open video ↗